research
From reasoning and recovery to sensing and soft robotic systems.
Diagnosing and recovering from manipulation failures
How can a robot understand why an action failed—and decide how to recover? My work on VLM-guided VLA fault recovery connects fault diagnosis with spatial corrections and temporal rollback decisions.
Related work: Can VLMs Diagnose and Recover from VLA Manipulation Faults? · ICML 2026
Soft robots and optical sensing
My earlier work spans soft robotic mechanisms, custom actuators, optical sensing hardware, finite element analysis, and system-level experiments.
I have also explored fiber-optic sensing, shape-sensing grippers, soft sensor simulation, and the integration of tactile information with robot learning.
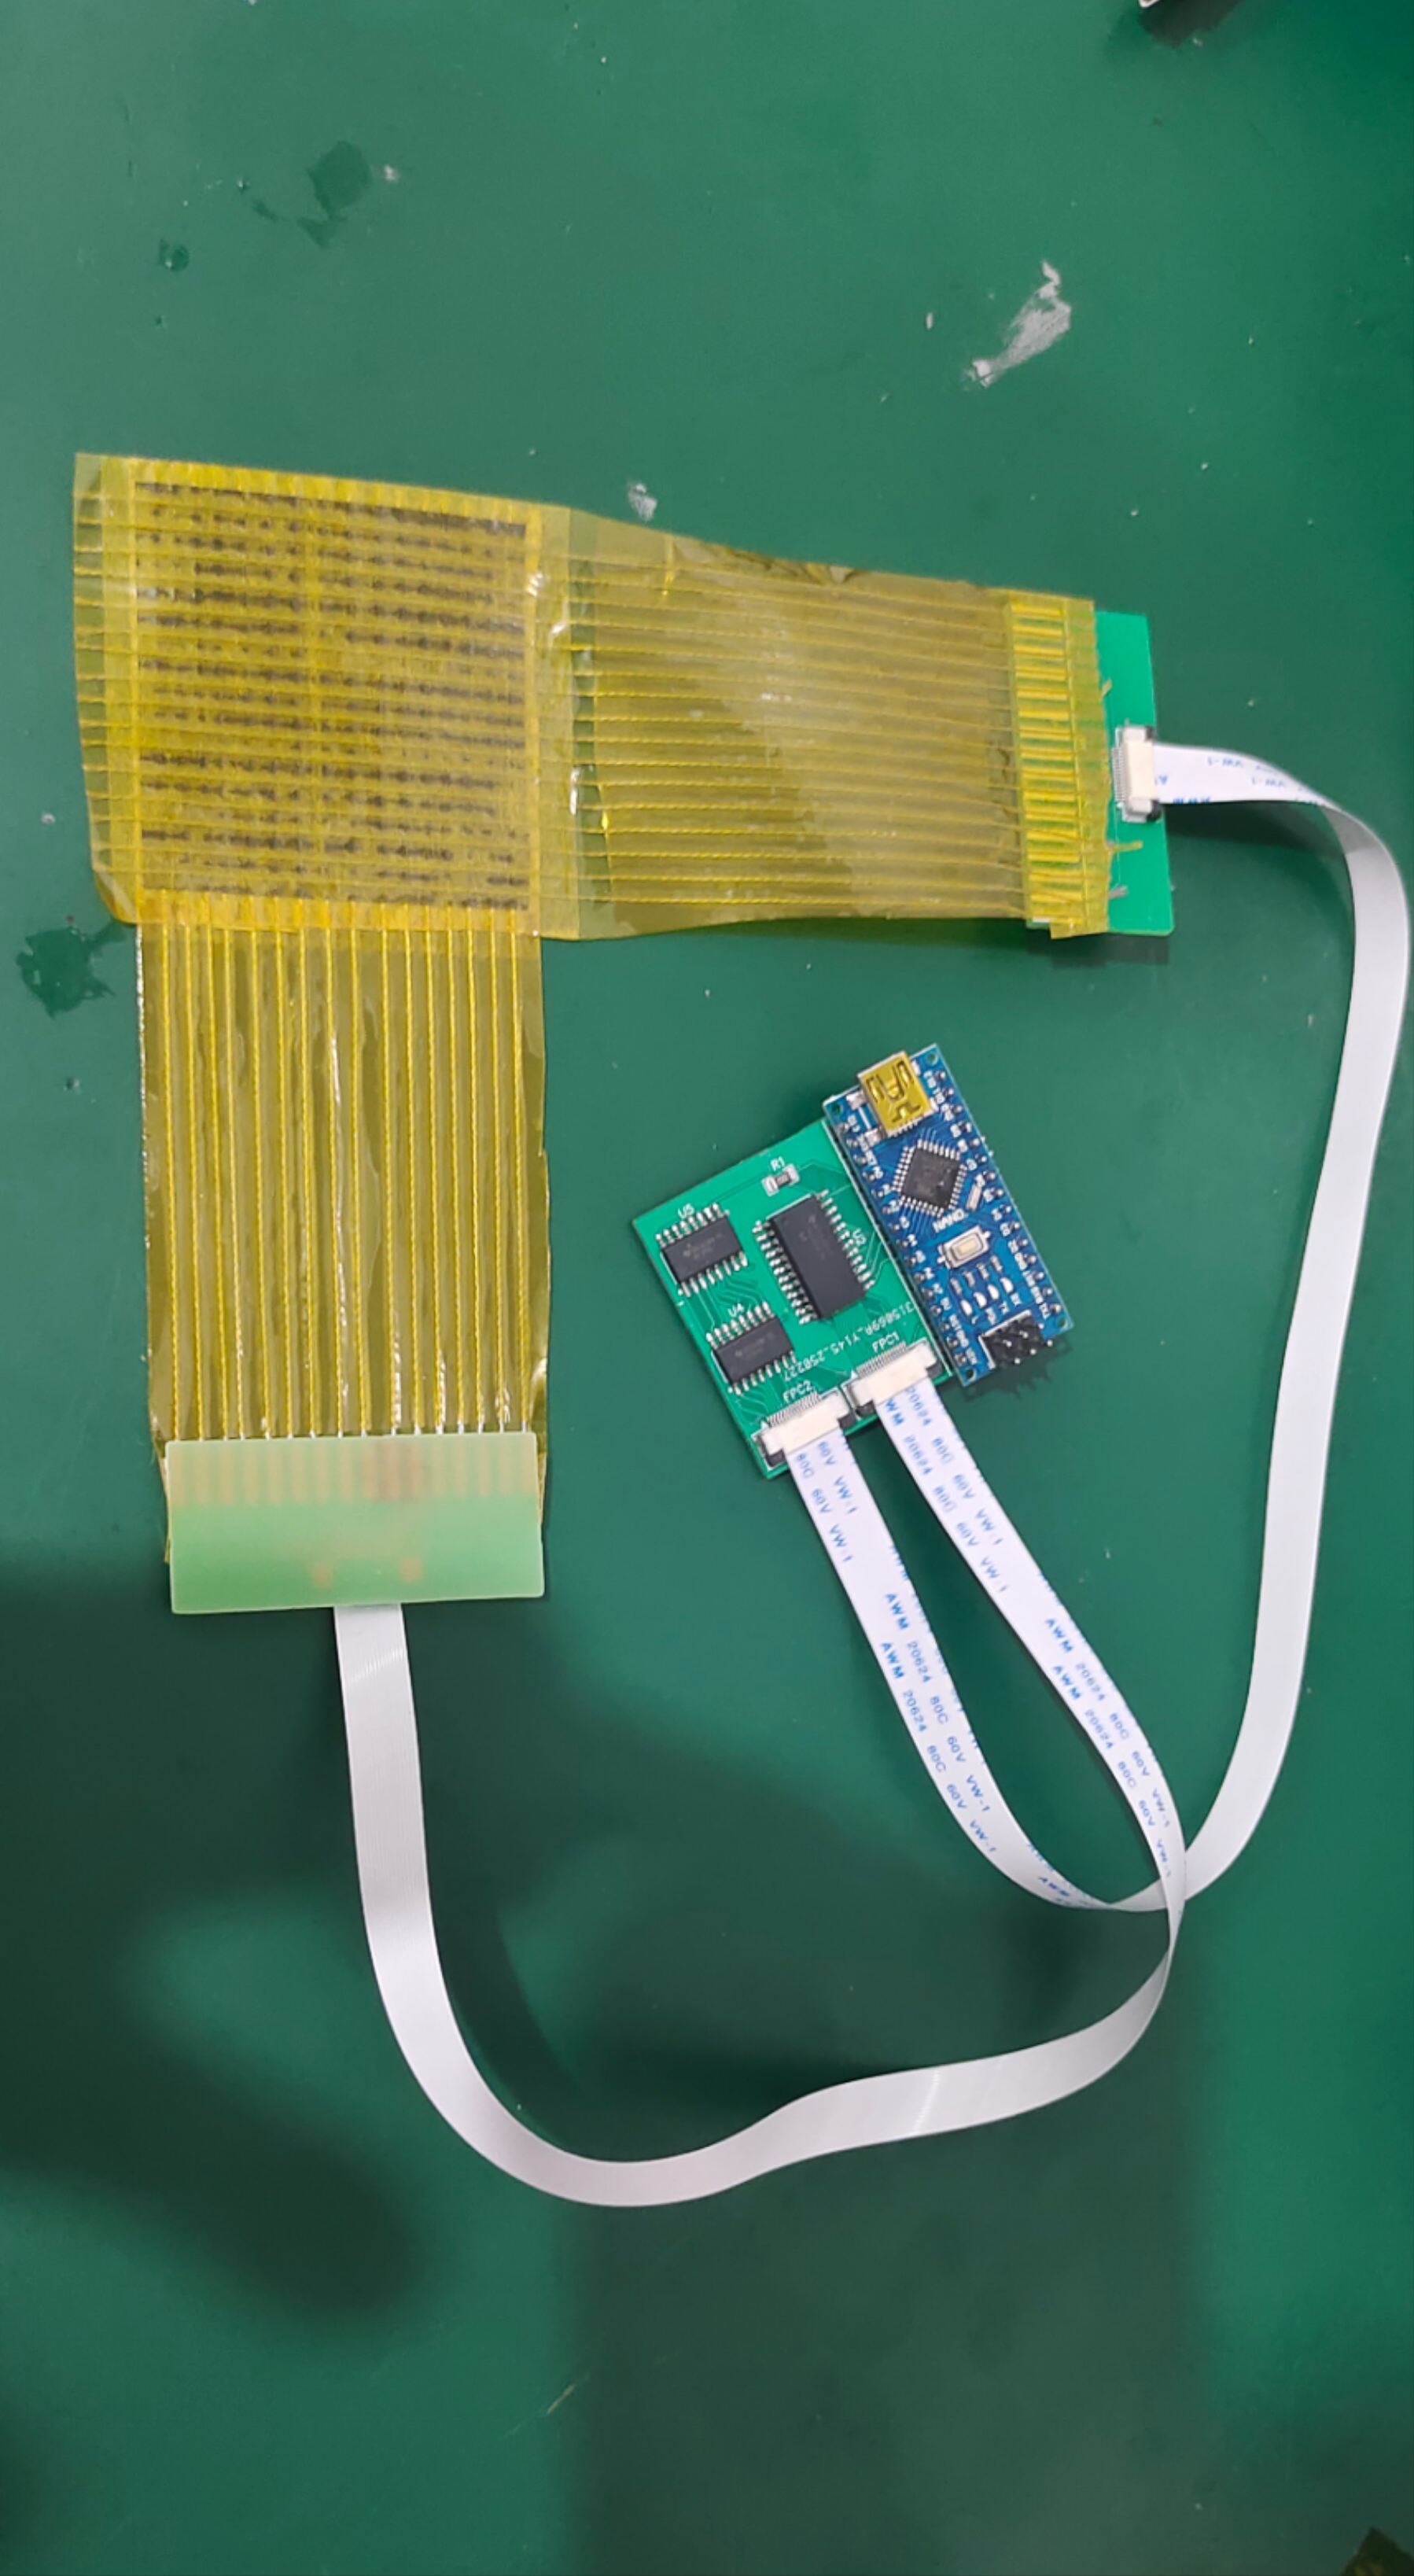
A sensing prototype from my earlier experimental work.
Experiments in simulation and tactile learning
These demonstrations document explorations of soft sensor simulation and tactile information in robot learning.